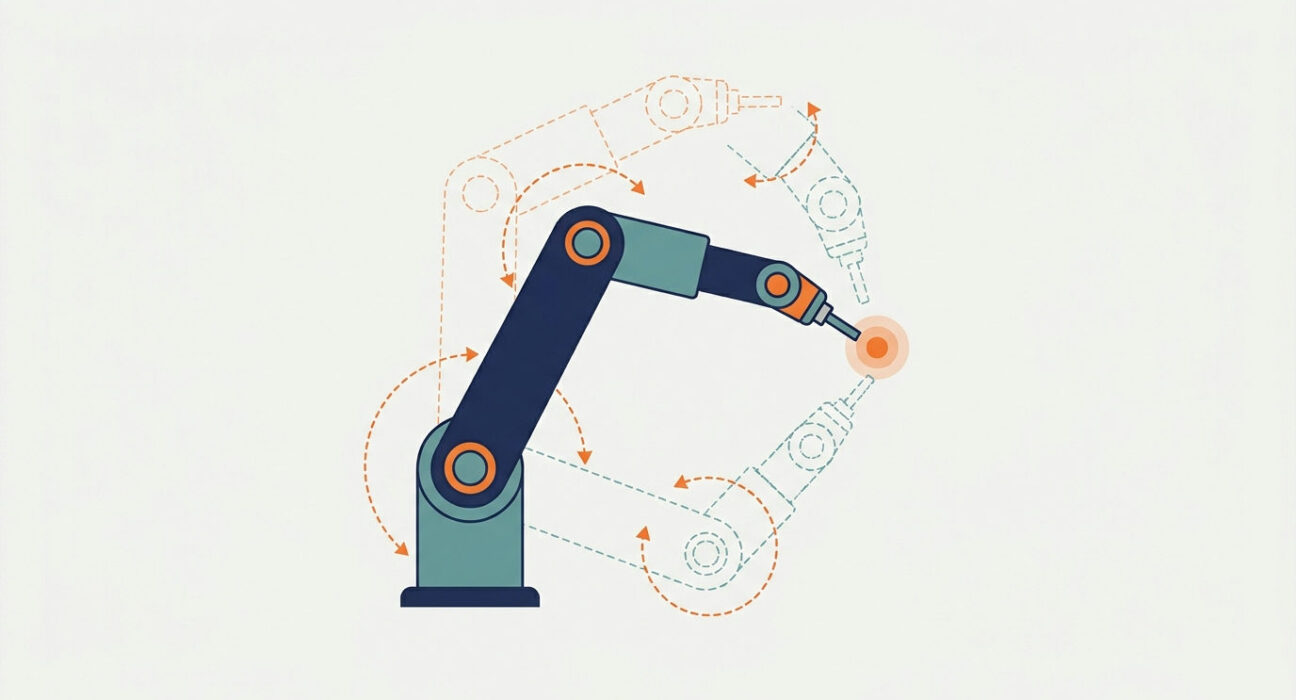
Inverse Kinematics Explained: How Robot Arms Work Out Their Joint Angles
Forward vs inverse kinematics in plain language, a two-joint arm solved by hand, analytical vs numerical solvers, and the joint limits, singularities and redundancy problems real robots face.